Enhancing the LLM-Based Robot Manipulation Through Human-Robot Collaboration
Aug 1, 2024· ,,,,,,·
1 min read
Haokun Liu
Yaonan Zhu
Kenji Kato
Atsushi Tsukahara
Izumi Kondo
Tadayoshi Aoyama
Yasuhisa Hasegawa
Abstract
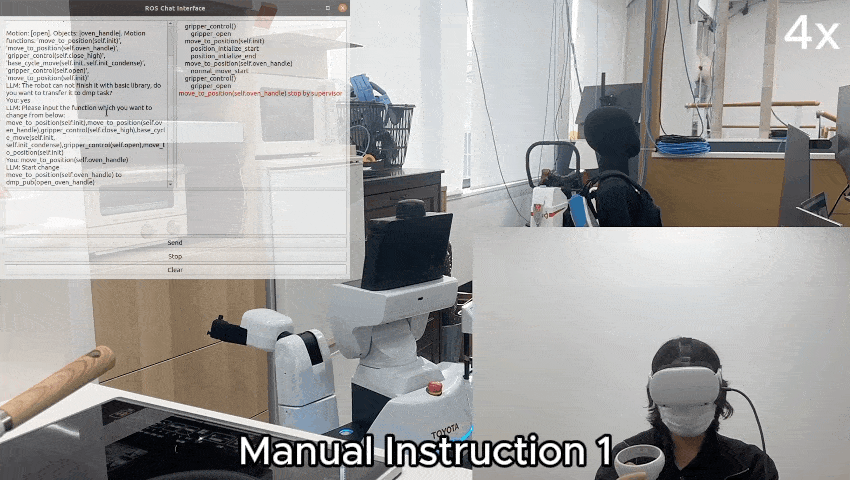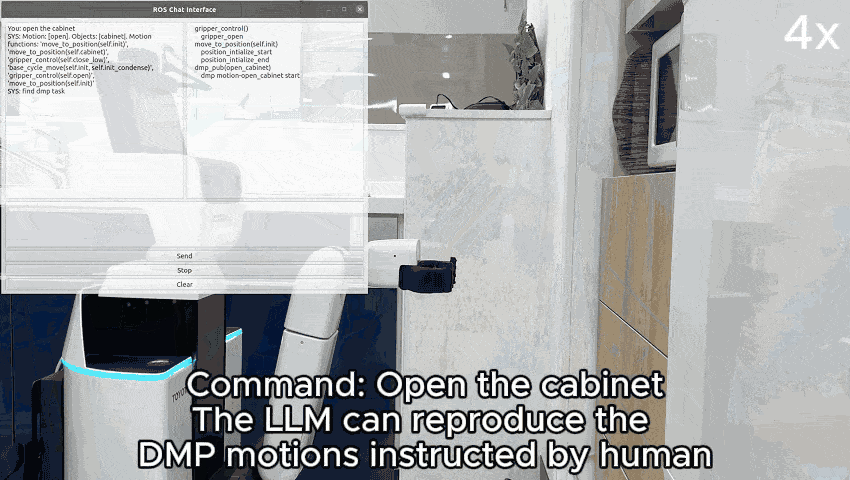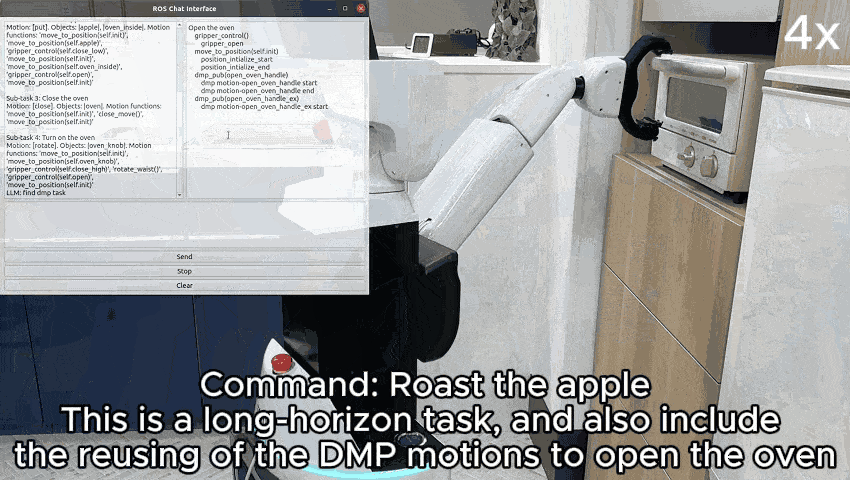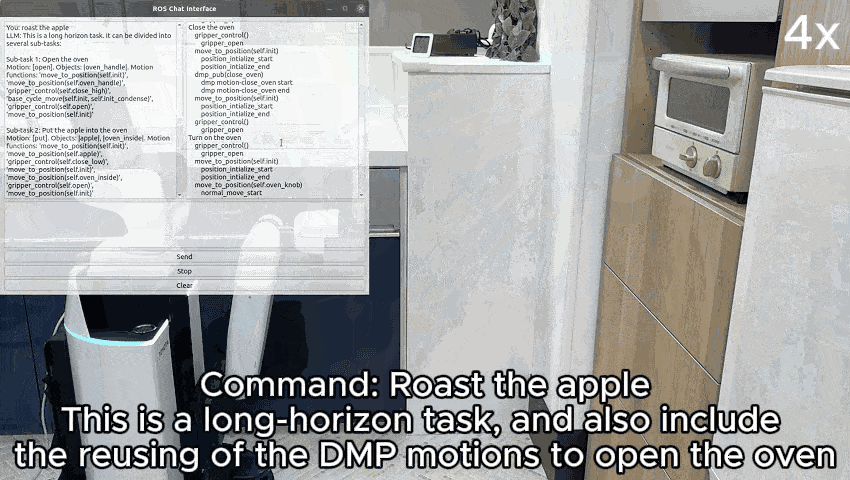
Large language models (LLMs) are gaining popularity in robotics, but LLM-based robots are limited to simple, repetitive motions due to the poor integration between language models, robots, and the environment. This paper proposes a novel approach to enhance the performance of LLM-based autonomous manipulation through human-robot collaboration (HRC). A prompted GPT-4 language model decomposes high-level language commands into sequences of motions executable by the robot, and a YOLO-based perception algorithm provides visual cues to the LLM for planning feasible motions within the specific environment. Furthermore, an HRC method combining teleoperation and dynamic movement primitives (DMP) allows the LLM-based robot to learn from human guidance.
Type
Publication
IEEE Robotics and Automation Letters, 9(8), 6904–6911
Video

Authors
PhD Student
I am a PhD student at the DRAGON Lab,
The University of Tokyo, advised by Junior Assoc. Prof.
Moju Zhao.
My research focuses on vision-language-action (VLA) models and
language-conditioned navigation for aerial and ground robots.