CoFL: Continuous Flow Fields for Language-Conditioned Navigation
Mar 1, 2026· ,,,,,,,·
1 min read
Haokun Liu
Zhaoqi Ma
Yicheng Chen
Masaki Kitagawa
Wentao Zhang
Zicen Xiong
Jinjie Li
Moju Zhao
Abstract
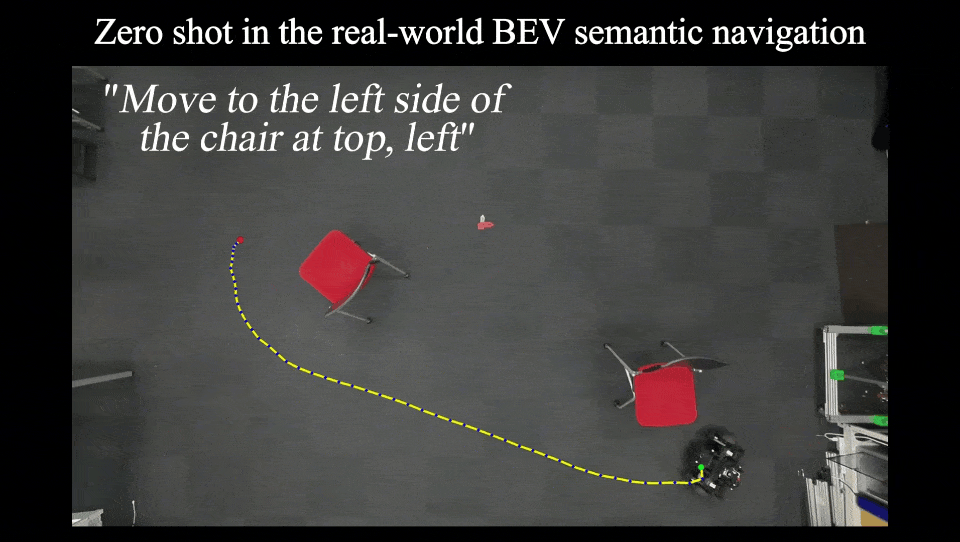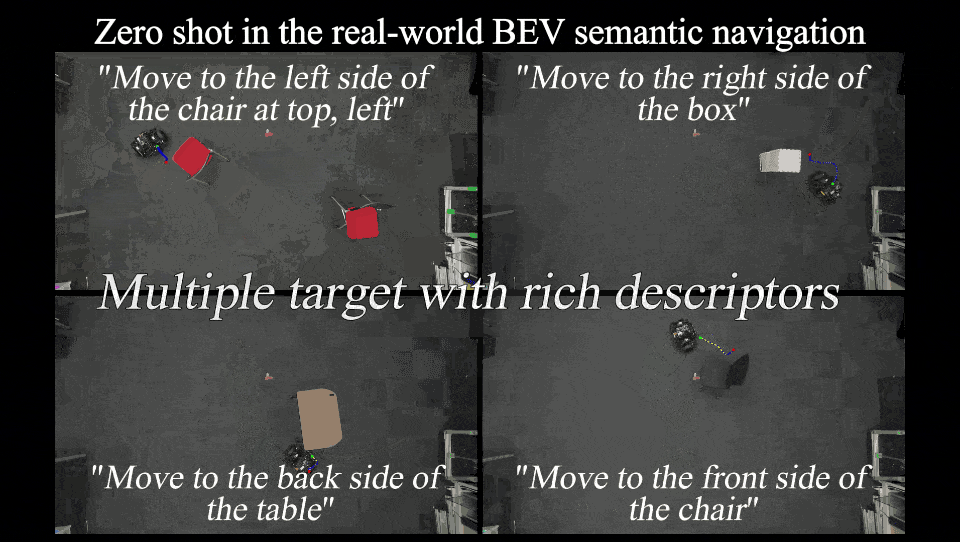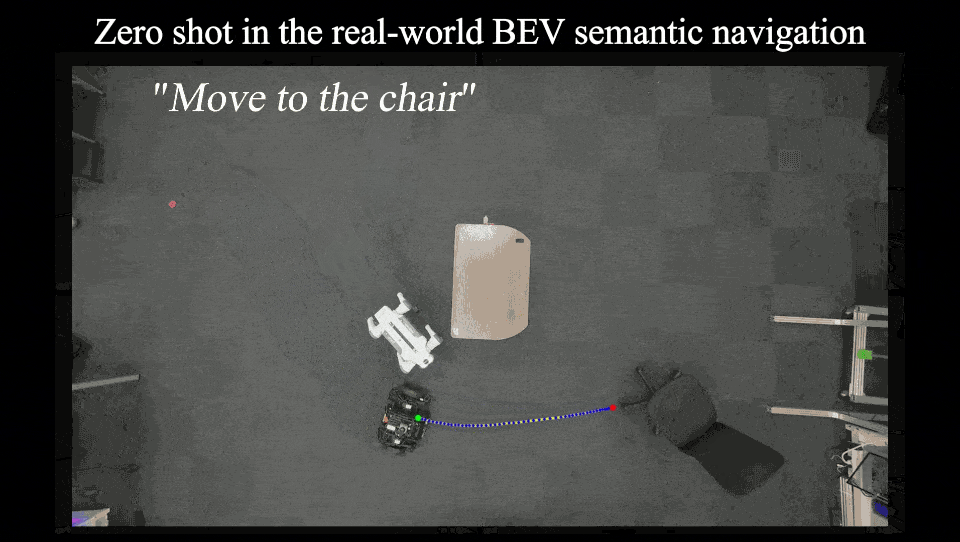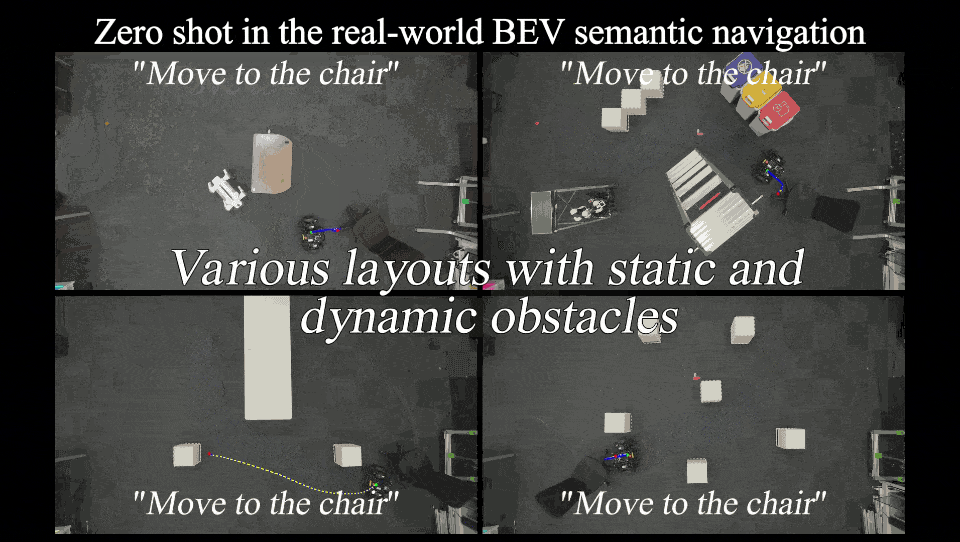
CoFL is an end-to-end policy that maps a bird’s-eye-view (BEV) observation and a language instruction to a continuous flow field for navigation, reformulating navigation as workspace-conditioned field learning rather than start-conditioned trajectory prediction. Trajectories are generated from any start point by numerically integrating the predicted field, enabling simple real-time rollout and closed-loop recovery. We build a dataset of over 500k BEV image–instruction pairs, each procedurally annotated with a flow field and trajectory derived from semantic maps built on Matterport3D and ScanNet. CoFL significantly outperforms modular VLM-based planners and trajectory generation policies, and is deployed zero-shot in real-world experiments.
Type
Publication
arXiv preprint (under review)
Video

Authors
PhD Student
I am a PhD student at the DRAGON Lab,
The University of Tokyo, advised by Junior Assoc. Prof.
Moju Zhao.
My research focuses on vision-language-action (VLA) models and
language-conditioned navigation for aerial and ground robots.