Hierarchical Language Models for Semantic Navigation and Manipulation in an Aerial-Ground Robotic System
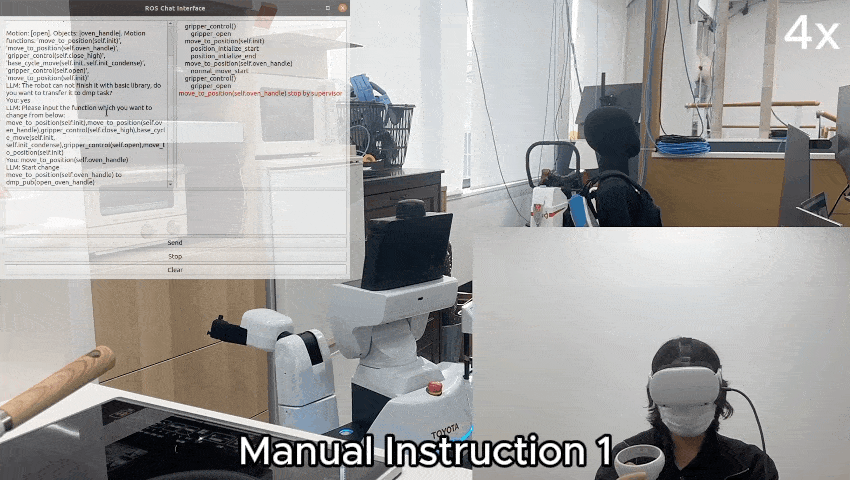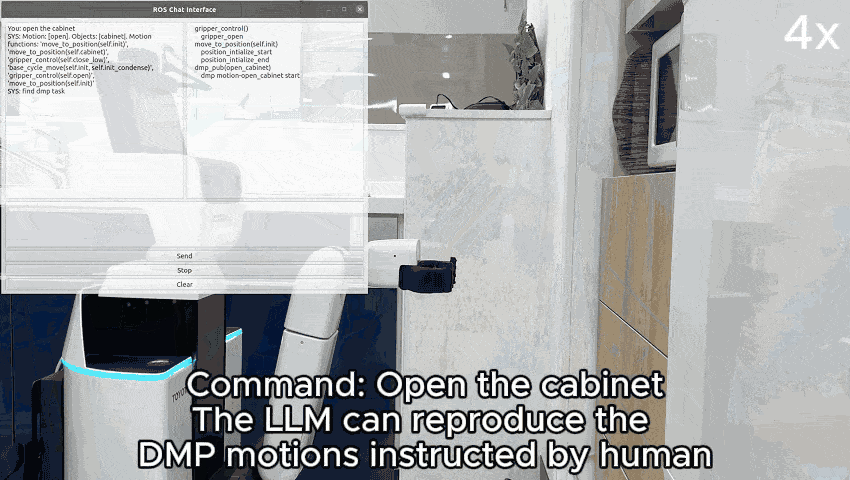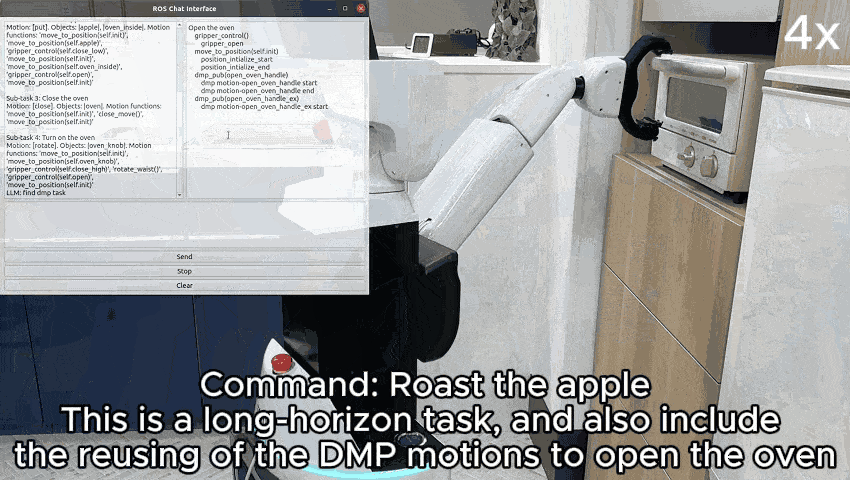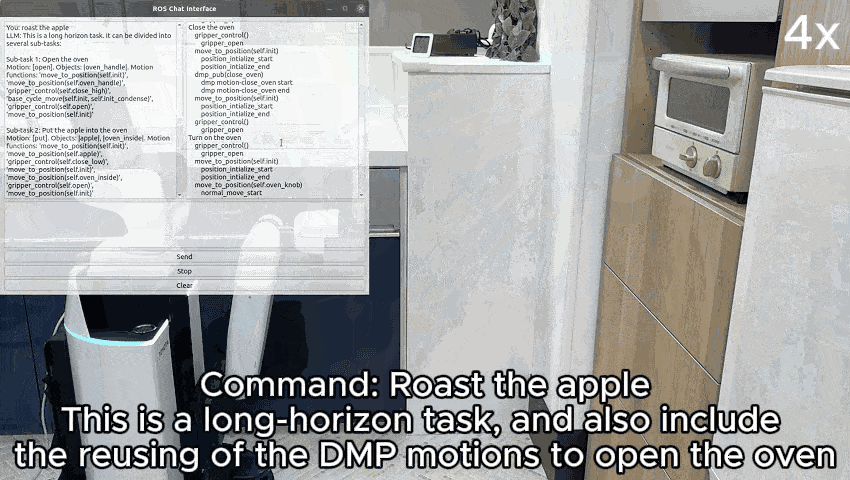
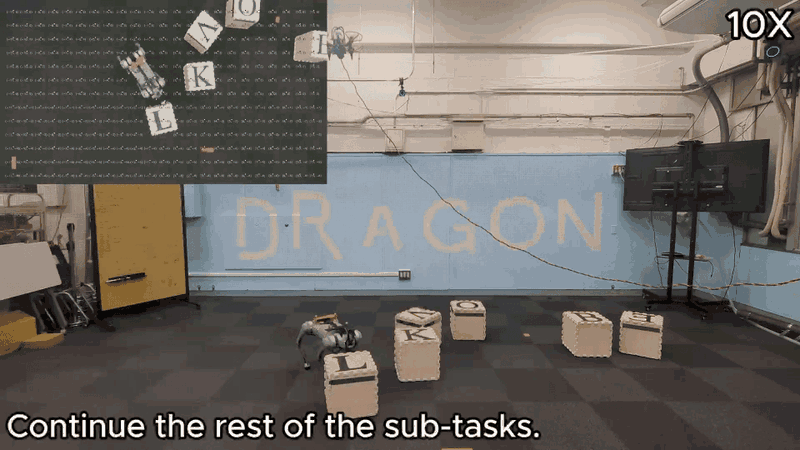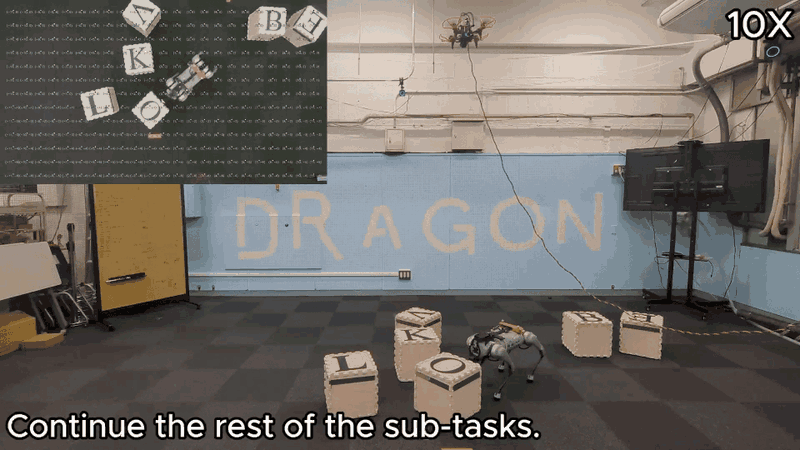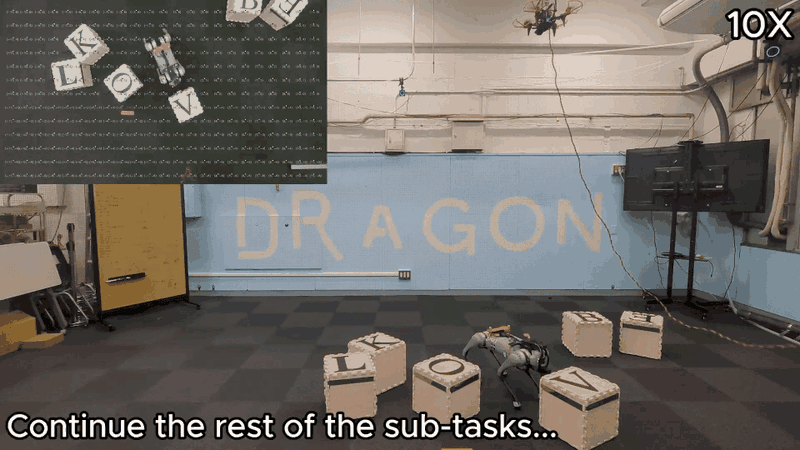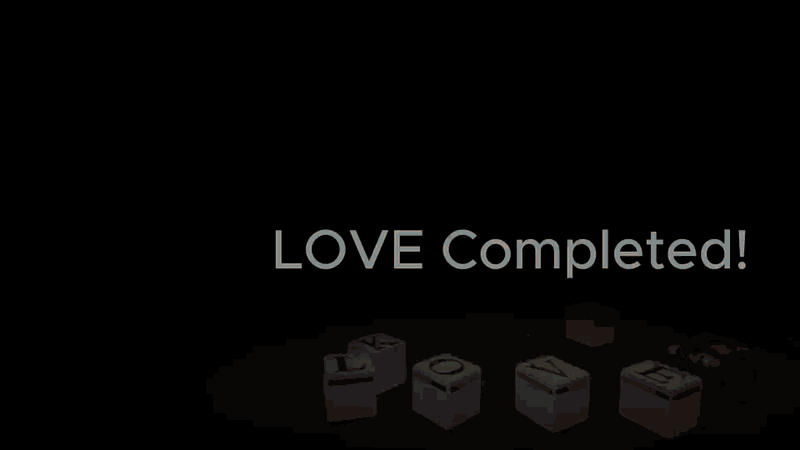
A hierarchical LLM + VLM framework for an aerial-ground heterogeneous robot team: the drone builds a global semantic map and guides the ground robot's local semantic navigation and …