🎉 CoFL-S accepted to CoRL 2026
Sep 7, 2026· ·
1 min read
Haokun Liu
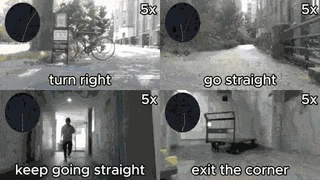
Our paper CoFL-S: Spatially Queryable Sector Flow Fields for Local Language-Conditioned Navigation has been accepted to the Conference on Robot Learning (CoRL) 2026!
CoFL-S is a low-level vision-language-action framework that predicts a language-conditioned flow field over the robot’s local visible sector and rolls it out into continuous trajectories. It is trained with frame-level local supervision distilled from VLN-CE episodes.
- Paper page: CoFL-S
- arXiv: 2607.02222
- Video: YouTube
Many thanks to all my co-authors and to my advisor Moju Zhao. See you at CoRL!

Authors
PhD Student
I am a PhD student at the DRAGON Lab,
The University of Tokyo, advised by Junior Assoc. Prof.
Moju Zhao.
My research focuses on vision-language-action (VLA) models and
language-conditioned navigation for aerial and ground robots.