Haokun Liu

Haokun LiuHàokūn Liú

PhD Student

The University of Tokyo

Professional Summary

I am a PhD student at the DRAGON Lab, The University of Tokyo, advised by Junior Assoc. Prof. Moju Zhao. My research focuses on vision-language-action (VLA) models and language-conditioned navigation for aerial and ground robots.

Education

PhD, Department of Mechanical Engineering

2024-10-01

The University of Tokyo

MEng, Department of Mechanical Systems Engineering

2022-10-01
2024-09-30

Nagoya University

BEng, Mechanical Design, Manufacturing and Automation

2018-09-01
2022-06-30

Hunan University

Interests

Vision-Language-Action Models Language-Conditioned Navigation Aerial-Ground Robotic Systems Human-Robot Collaboration
📚 My Research

My research focuses on vision-language-action (VLA) models for robots — enabling aerial and ground robots to understand natural-language instructions and act autonomously in the real world. I am also interested in vision-and-language navigation and learning-based robot control.

Please feel free to reach out if you are interested in collaboration 😃

Featured Publications
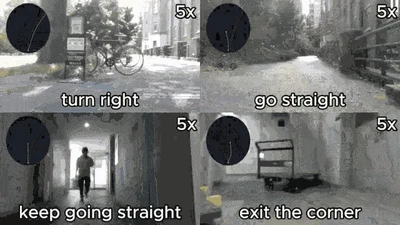
CoFL-S: Spatially Queryable Sector Flow Fields for Local Language-Conditioned Navigation featured image

CoFL-S: Spatially Queryable Sector Flow Fields for Local Language-Conditioned Navigation

A spatially queryable sector flow-field representation for local language-conditioned navigation, trained with frame-level supervision distilled from VLN-CE episodes.

avatar
Haokun Liu
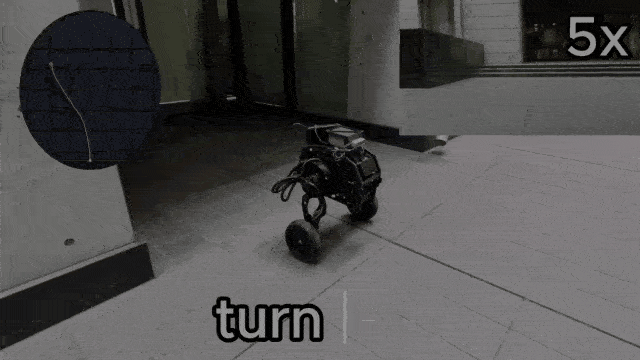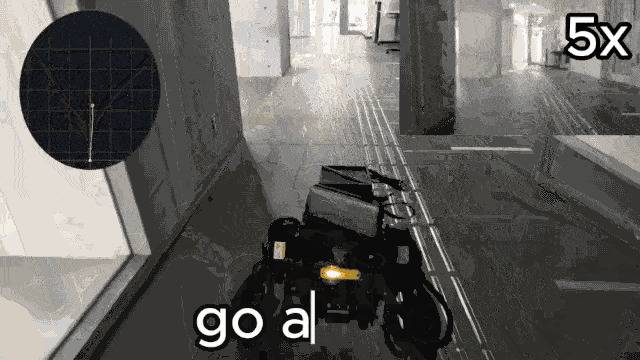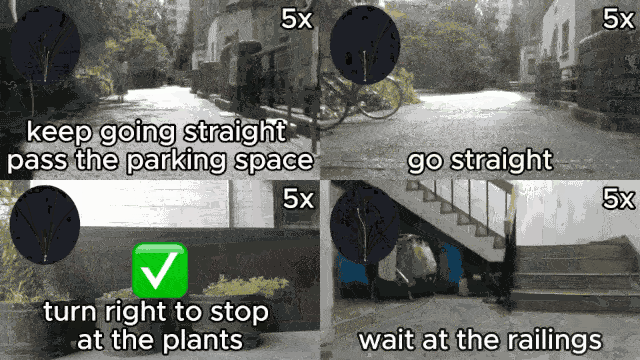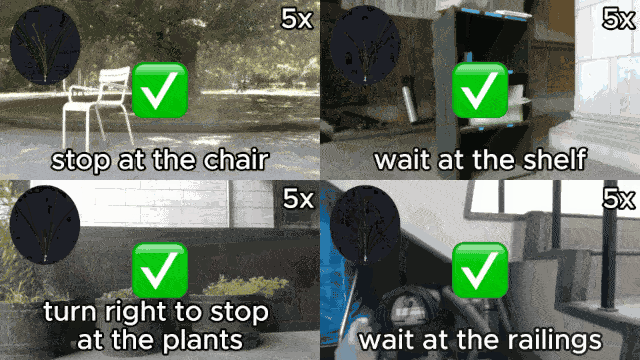
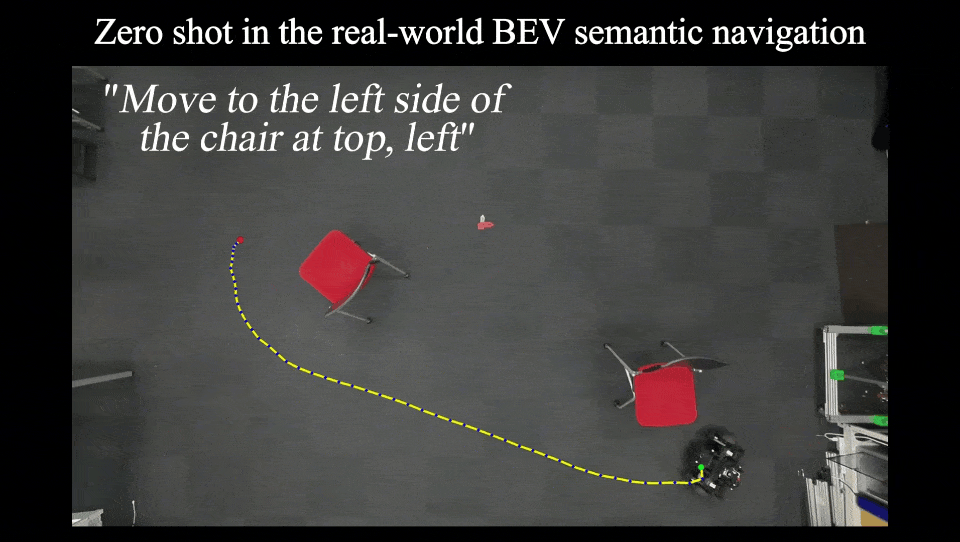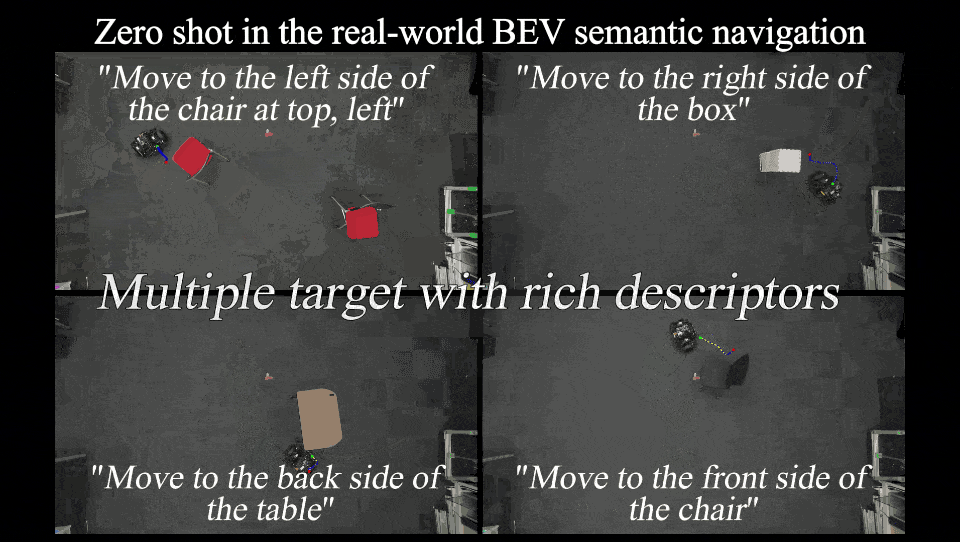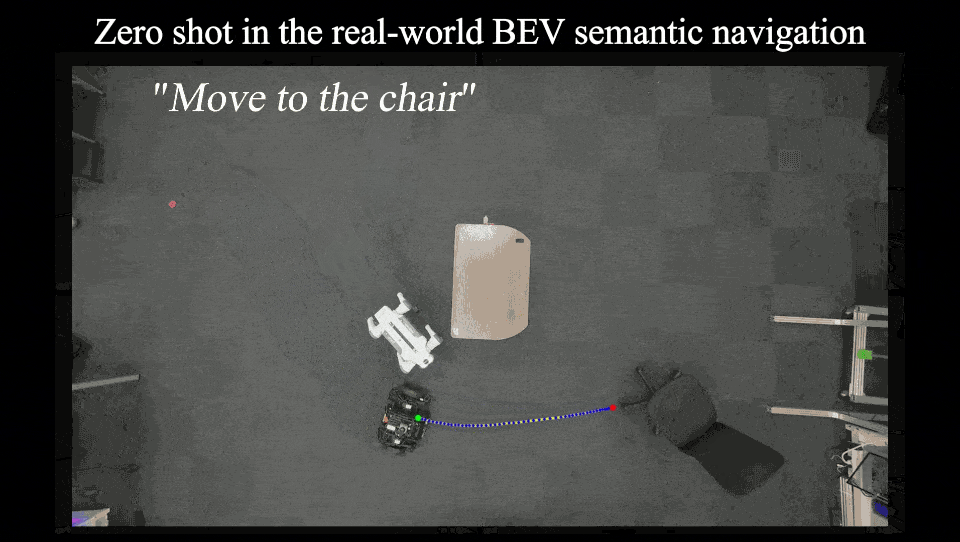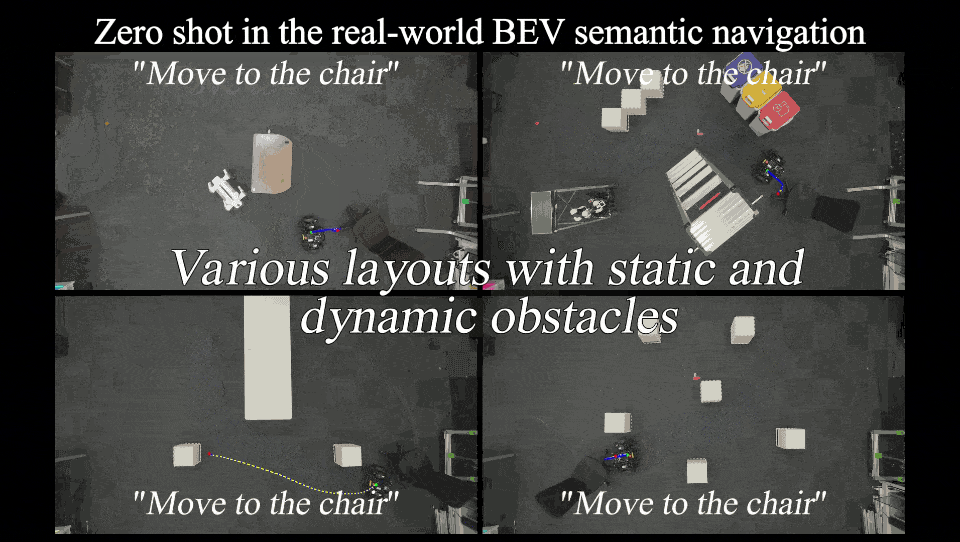
CoFL: Continuous Flow Fields for Language-Conditioned Navigation featured image

CoFL: Continuous Flow Fields for Language-Conditioned Navigation

Reformulates language-conditioned navigation as learning a continuous flow field over the workspace: trajectories from any start point by field integration, trained on 500k+ …

avatar
Haokun Liu
Hierarchical Language Models for Semantic Navigation and Manipulation in an Aerial-Ground Robotic System featured image

Hierarchical Language Models for Semantic Navigation and Manipulation in an Aerial-Ground Robotic System

A hierarchical LLM + VLM framework for an aerial-ground heterogeneous robot team: the drone builds a global semantic map and guides the ground robot's local semantic navigation and …

avatar
Haokun Liu
Enhancing the LLM-Based Robot Manipulation Through Human-Robot Collaboration featured image

Enhancing the LLM-Based Robot Manipulation Through Human-Robot Collaboration

Improves LLM-based autonomous manipulation by combining GPT-4 task decomposition and YOLO-based perception with human-robot collaboration via teleoperation and dynamic movement …

avatar
Haokun Liu
Recent Publications
Recent & Upcoming Talks
Recent News
🎉 CoFL-S accepted to CoRL 2026 featured image

🎉 CoFL-S accepted to CoRL 2026

Our paper "CoFL-S: Spatially Queryable Sector Flow Fields for Local Language-Conditioned Navigation" has been accepted to the Conference on Robot Learning (CoRL) 2026.

avatar
Haokun Liu
🎉 Website launched featured image

🎉 Website launched

My personal academic homepage is now online.

avatar
Haokun Liu